Research, on the house.
Up to 100 hours filmed to your brief, free, for a citation.
Applications openuntil , 23:59 IST
The deal.
| Term | Value | What it means |
|---|---|---|
| Hours | up to 100 h | Per lab, split across the workplaces you pick, in steps of 10 h. Plan them in the brief |
| Cost | none | No fee and no invoice. |
| Citation | one, with the batch id | In every paper, preprint, thesis or release that uses the data, in the format we give. The citation |
| Data use | your named project | Train, evaluate and publish results, figures and still frames. No redistribution or re-hosting, no attempt to identify a worker or a site. The data-use summary |
| Deadline | 30 November 2026 | Applications close at the end of that day (IST). Collection follows acceptance, in batches as hours pass review. How it runs |
| Release | agreed in writing | Your own release (internal use only, a derived dataset or benchmark, model weights trained on it) is agreed before collection starts. Hours collected for you go into our planned open release only if you say so. The open release |
A plain-words summary; the binding terms come with the acceptance letter.
Where you start.
Five things on this site you can inspect before you apply.
1 From the workplaces
Footage
![]()
LaundryFV-Z00906 · 430.0–438.0 s
![]()
HVAC servicesFV-C01730 · 600.0–608.0 s
![]()
MetalFV-B01919 · 620.0–628.0 s
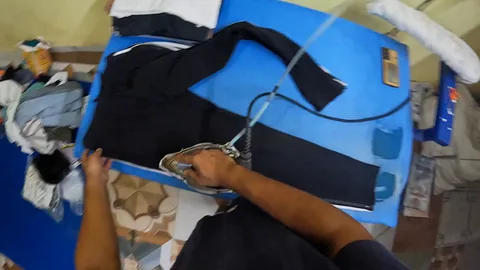
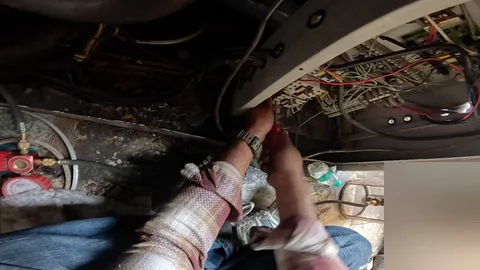
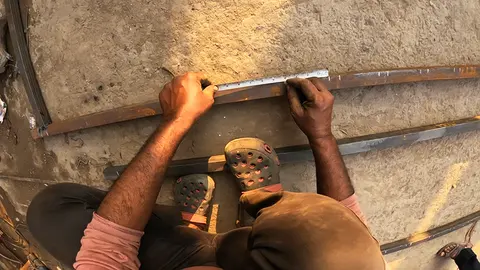
Cut for this page: none of these clips plays anywhere else on the site.
Notes (3)
- FV-Z00906 · 430.0–438.0 s: camera file 2704×1520 · 59.94 fps
- FV-C01730 · 600.0–608.0 s: camera file 1920×1080 · 29.97 fps; blurred: the refrigerant cylinder's QR-code label; the same label, lower in the frame.
- FV-B01919 · 620.0–628.0 s: camera file 1920×1080 · 29.97 fps
Every workplace and its tasks, in the catalogueMore clips play on the home wall
5 A finding about hands at work
Eight directions hold 91.8% of the posture variance.
55,088 estimated wearer hand poses from four trades: a descriptive finding, not a training result.
The directions, with the hands at work: home, Fig. 48 of 16 hold 91.8% of the variance
For work you'll publish.
Apply if you are
- A research group at a university or public research institute, with a named principal investigator.
- Working on a defined research use: a model, a benchmark or a study.
- A corporate research lab: we decide case by case.
Not for
- Training a commercial product. Ask for a quote instead.
One citation, clear rules.
Use the batch id from each batch's README, so readers can tell which hours you used.
Plain text
Four-Vectors Automation Private Limited (2026). kollected.ai: first-person video of real manual work with inertial data and action labels. Research data partnership, batch <BATCH-ID>, taxonomy v1.0.0. https://kollected.aiBibTeX
@misc{kollected2026,
  author       = {{Four-Vectors Automation Private Limited}},
  title        = {kollected.ai: first-person video of real manual work with inertial data and action labels},
  year         = {2026},
  howpublished = {\url{https://kollected.ai}},
  note         = {Research data partnership, batch <BATCH-ID>; taxonomy v1.0.0}
}You may
- train and evaluate models on it
- publish results, figures and still frames from it
- share it with the co-authors and students of the project you named
- keep it after the programme ends, for that project
You may not
- redistribute or re-host the files, in whole or in part
- try to identify a worker, a colleague or a site
- use it for a project you did not name, without asking
- sell it, or build a dataset product from it
We
- keep the consent record of every batch and show it on request
- never publish who our partners are, unless you ask us to
Write your brief.
Your answers write the brief; nothing is sent until you press Send.
From brief to batch.
01 Apply
Send the brief you build above.
02 We reply
By email, with a yes, a question or a no, and the hours we can commit.
03 Shot list and consent
Before the first clip, your picks become a shot list for each site.
04 Collection
Only clips that pass the acceptance gates enter a delivery.
05 Delivery
In batches, by signed link or to your own bucket.
Shot list
Each site's shot list is drawn from the taxonomy, so the footage covers distinct tasks, not one repeated motion.
The taxonomy, as JSONConsent
Workers sign a written licence for machine-learning training; anyone regularly in shot signs a consent form.
Read the consent policyAcceptance gates
- both hands in at least 90% of frames
- no continuous idle stretch over 10 s
- an identifiable face in at most 5% of frames
What you receive, per clip
- FV-B00023/
- FV-B00023.MP4original camera file, telemetry intact
- FV-B00023_imu.csvtimestamp_us, ax, ay, az, gx, gy, gz
- FV-B00023_labels.jsonordered segments with ENV.C.SS codes
- FV-B00023_meta.jsondevice, mount, site, collector, consent
Formats on request: LeRobot v3, RLDS, HDF5, MCAP. The originals always ship.
Straight from the files.
Every value is read from the data at build; a dash means unmeasured.
One 10 s clip, four streams, on the video clock
Data only: we publish this clip's motion data, not its picture. Drag across any plot, or focus the time bar and use the arrow keys.
Accelerometerm/s²
ax —ay —az —
Camera axes; gravity is not removed.
Gyroscoperad/s
gx —gy —gz —
Camera axes.
Orientation°
heading —pitch —roll —
Inertial attitude filter (madgwick-imu); heading 0 at the clip's start.
Positionm
x —y —z —
Inertial estimate, not a surveyed path.
| Channel | Unit | Min | Max |
|---|---|---|---|
| ax | m/s² | -5.197 | -0.211 |
| ay | m/s² | 7.472 | 11.252 |
| az | m/s² | -1.492 | 1.525 |
| gx | rad/s | -0.454 | 0.424 |
| gy | rad/s | -0.622 | 0.407 |
| gz | rad/s | -0.161 | 0.209 |
The sidecar stores int16 at 1/200 (accelerometer) and 1/500 (gyroscope) of the unit; the delivered CSV is full precision.
| Field | Value |
|---|---|
| Orientation | Inertial attitude filter (madgwick-imu, β 0.05), gyro bias assumed zero (no still segment in this clip), 5 s pre-roll |
| Heading drift bound | — |
| Heading · pitch · roll | -3.7 to 7.5° · -6.2 to 6.6° · 13.6 to 20.8° |
| Position source | imu-estimate |
| Position note | Inertial estimate: gravity-removed acceleration integrated twice with a zero-mean-velocity prior over the clip. Drift-limited; shows sway, not a surveyed path. |
| Position range | x -0.04 to 0.04 m · y -0.09 to 0.14 m · z -0.02 to 0.03 m |
A SLAM trajectory is delivered where the footage supports it; this clip has none.
| Clip | Workplace | Frame | fps | Length | Inertial | Rate, measured | IMU rows | Labels |
|---|---|---|---|---|---|---|---|---|
| FV-B00023 | 15 Metal | 5312×2988 | 59.94 | 588.7 s | yes | 197.65 Hz | 116,526 | 1 · first-pass |
| FV-B00325 | 6 HVAC services | 1920×1080 | 59.94 | 589.4 s | yes | 197.36 Hz | 116,360 | 1 · first-pass |
| FV-B01919 | 15 Metal | 1920×1080 | 29.97 | 704.7 s | yes | 201.13 Hz | 141,734 | 1 · first-pass |
| FV-C00456 | 9 Carpentry | 3840×2160 | 50 | 442.3 s | yes | 200.81 Hz | 88,957 | 1 · first-pass |
| FV-Z00901 | 10 Kitchen | 2704×1520 | 100 | 440.0 s | yes | 196.98 Hz | 86,673 | 2 · first-pass |
| FV-Z00902 | 10 Kitchen | 1920×1080 | 30 | 120.1 s | no | — | — | 1 · first-pass · narrated |
| FV-Z00903 | 10 Kitchen | 1920×1080 | 30 | 120.7 s | no | — | — | 1 · first-pass · narrated |
| FV-Z00906 | 7 Laundry | 2704×1520 | 59.94 | 711.7 s | yes | 201.10 Hz | 143,125 | 1 · first-pass |
| FV-Z00907 | 10 Kitchen | 2704×1520 | 59.94 | 147.6 s | yes | 196.24 Hz | 29,071 | 1 · first-pass |
| FV-Z00908 | 10 Kitchen | 2704×1520 | 50 | 704.0 s | yes | 196.95 Hz | 138,653 | 2 · first-pass |
Most clips carry provisional ids; final ids are assigned at delivery.
An open release, planned.
About 1,000 hours, for anyone to inspect. Not live.
Footage, motion data and labels, planned for Hugging Face. Nothing goes up until its consent review and per-clip approvals are complete.
Who builds the pipeline.
Engineers working with the collection teams on capture, telemetry, labelling and delivery hold affiliations with Georgia Tech, Northwestern University, the University of Pennsylvania, IIT Roorkee, IIT Delhi, IIT Bombay and Carnegie Mellon University. These are individual engineers' affiliations; no institution endorses kollected or reviews its data.
Before you apply.
Yes, in the builder. Each task we can film gets a new code appended to the taxonomy; existing codes never change.
The 16 in the catalogue, all collecting now.
Still frames and figures, yes. Short clips in supplementary material, usually: ask first, and we check that faces stay under the 5% gate.
Buying for a product, or want to see the files first?