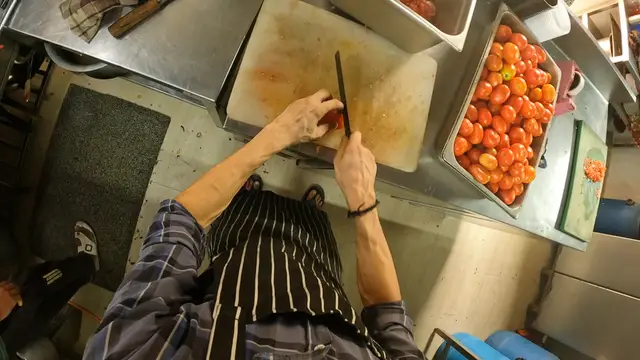

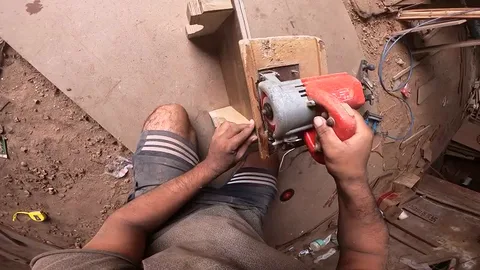
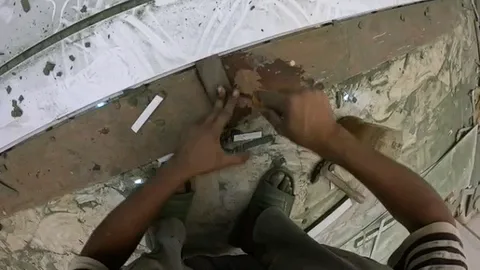
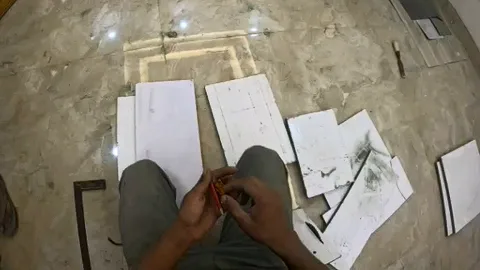
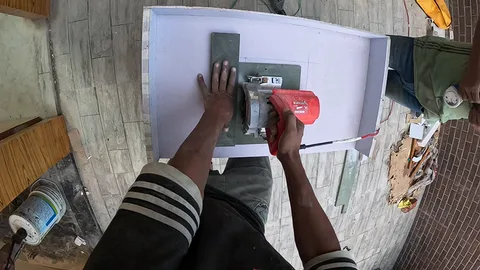
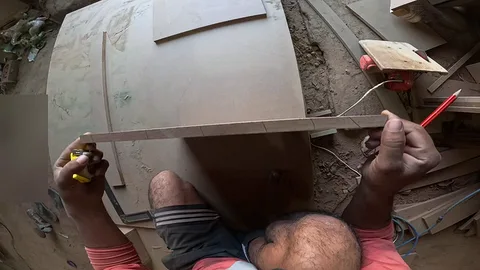
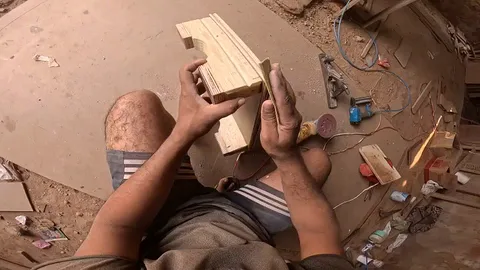
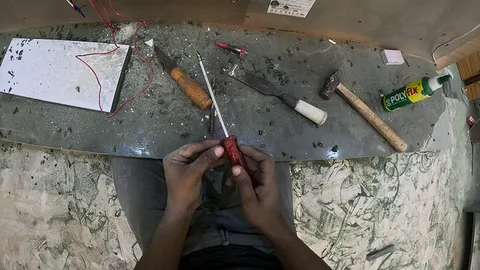
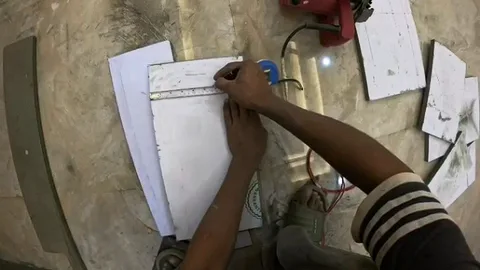
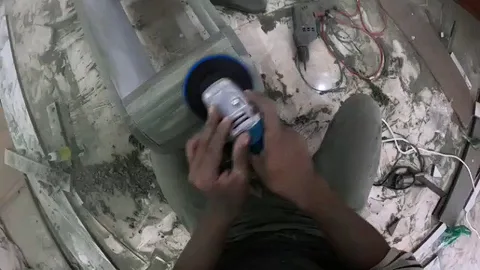
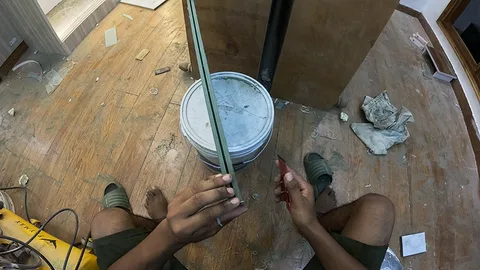
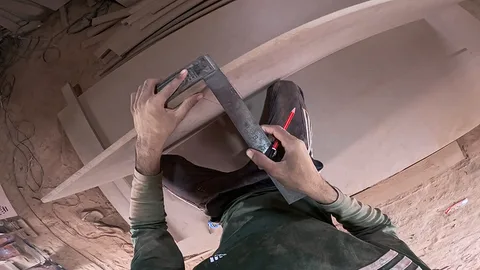
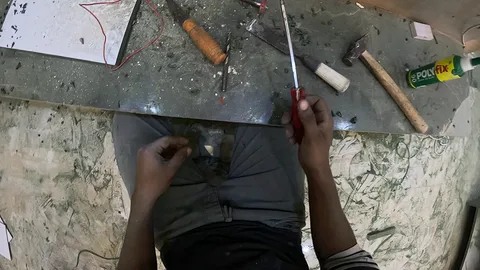
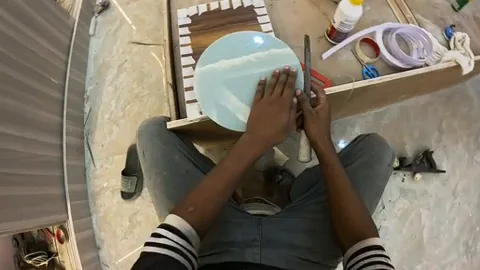
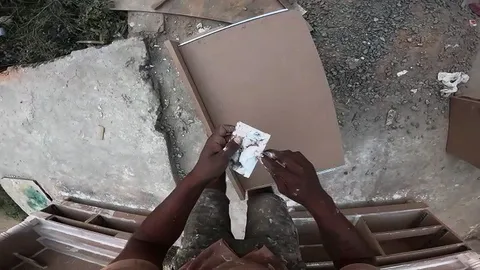
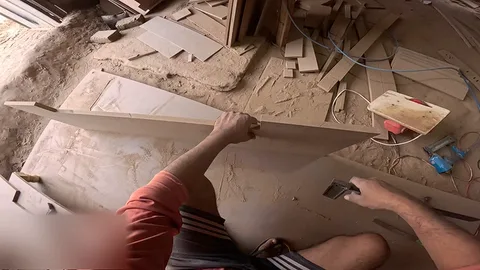
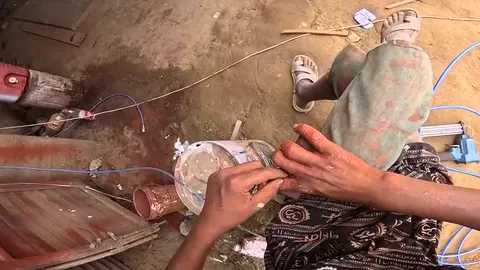
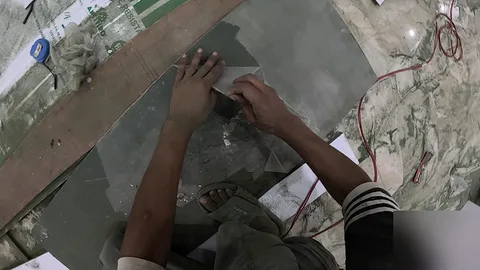
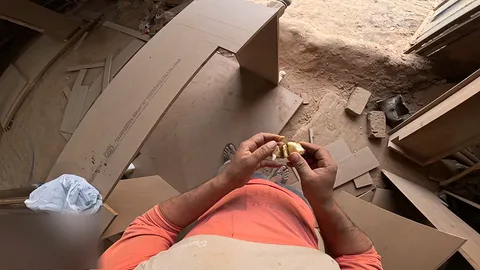
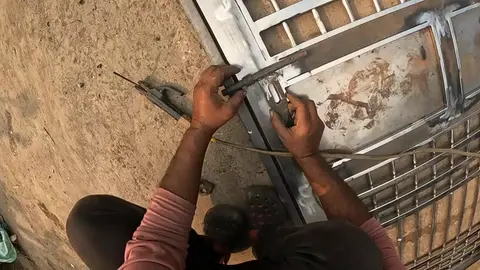
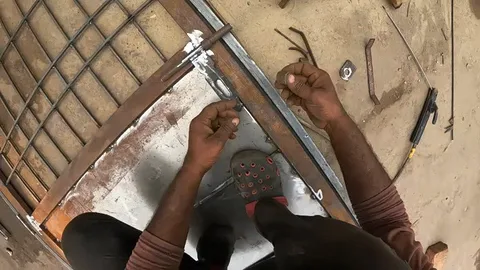
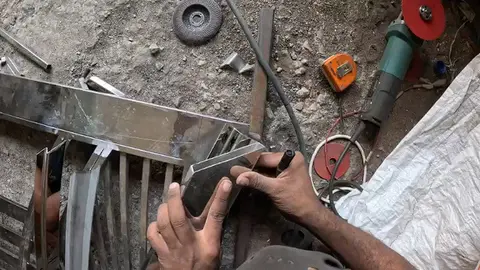
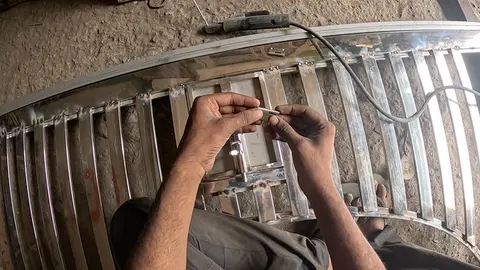
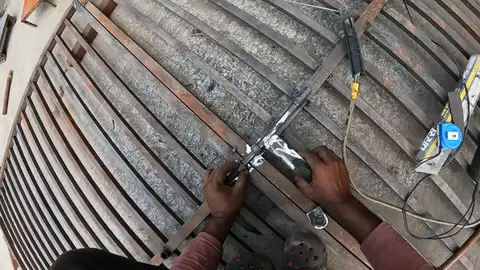
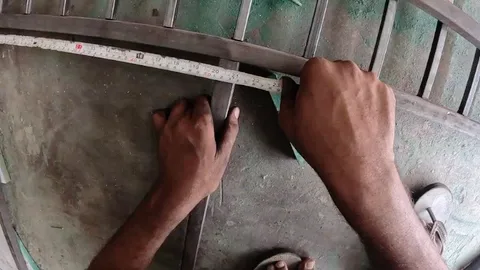
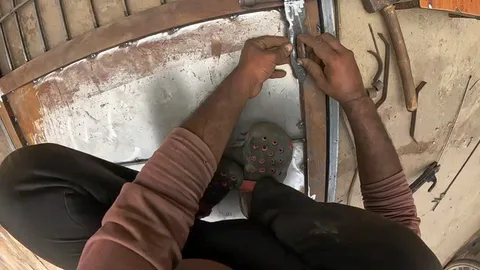
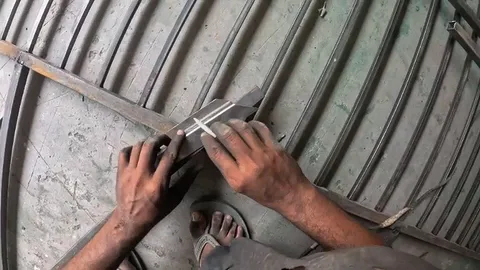
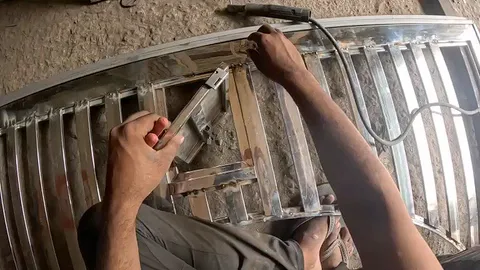
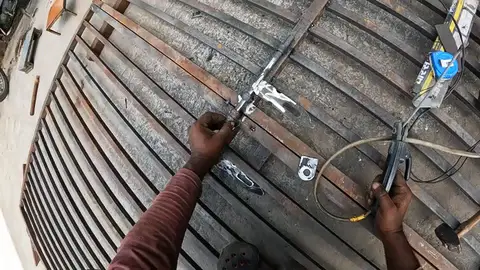
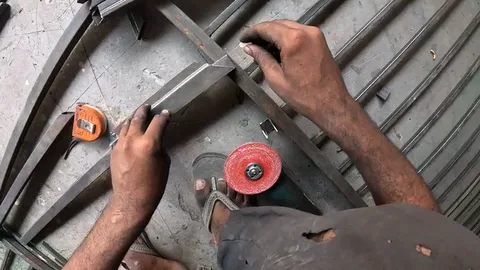
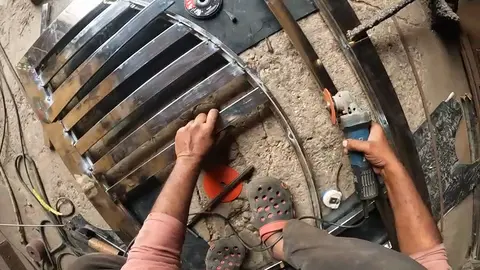
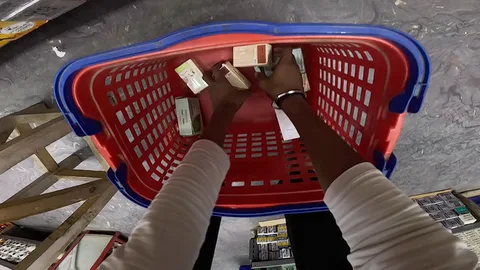
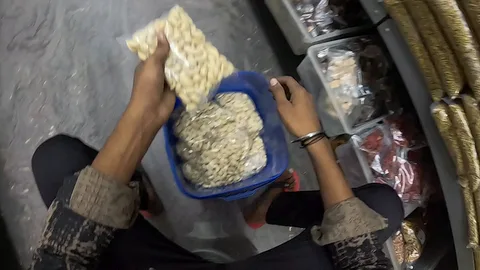
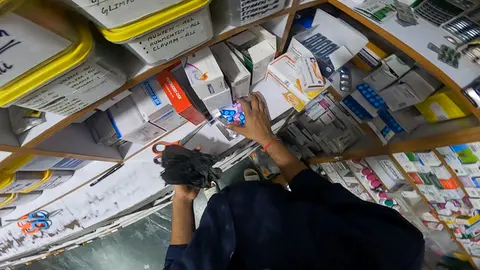
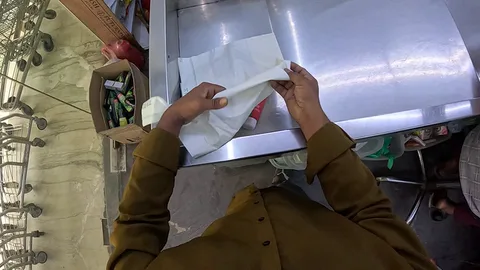
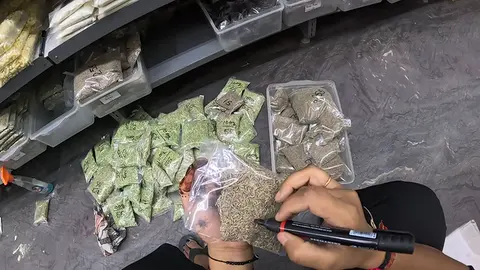
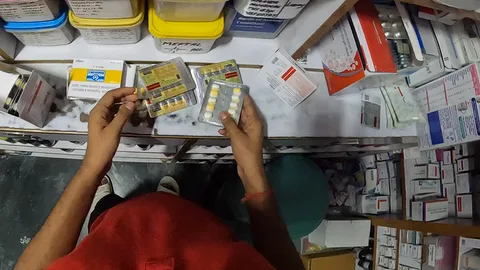
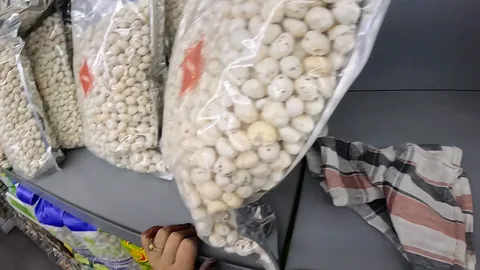
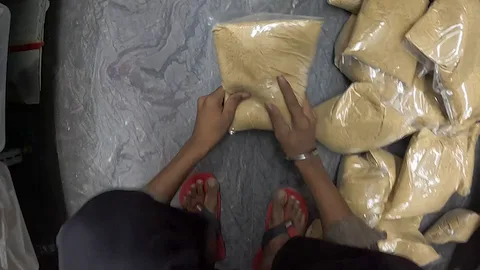
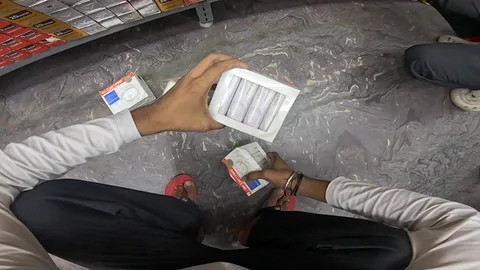
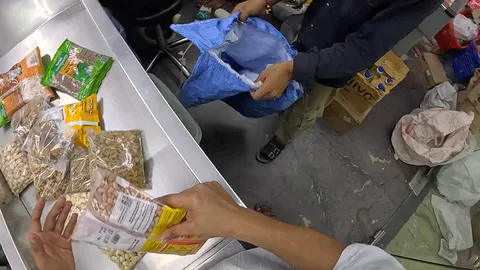
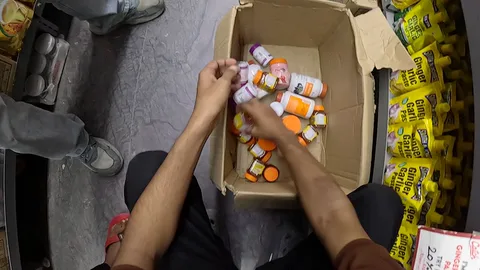
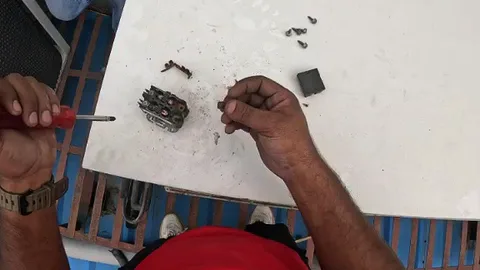
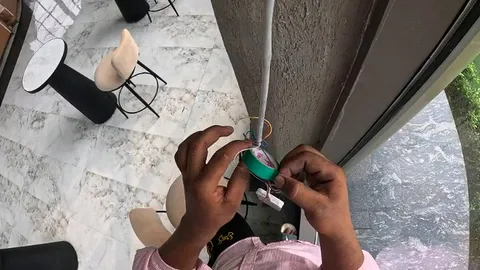
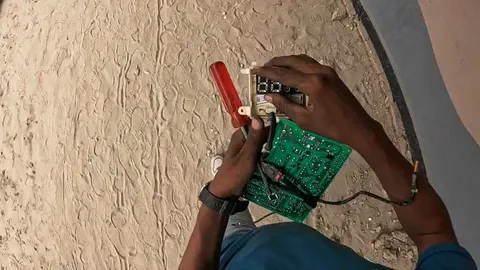
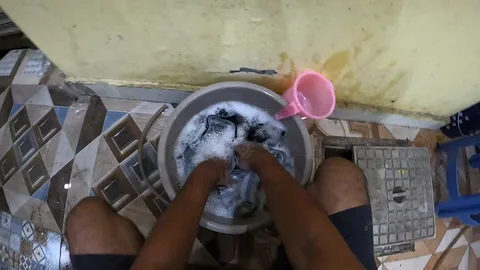
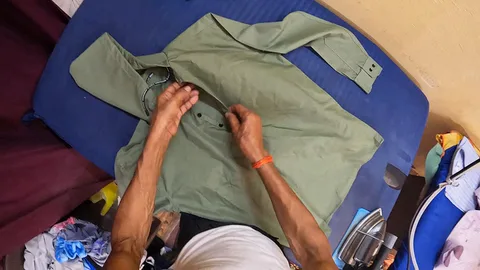
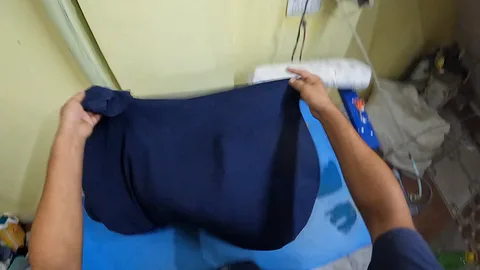
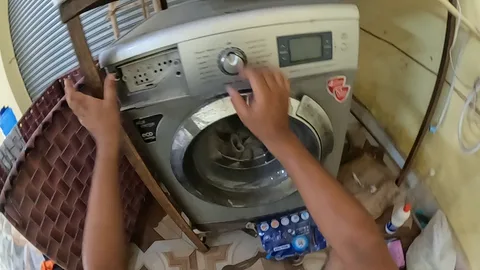
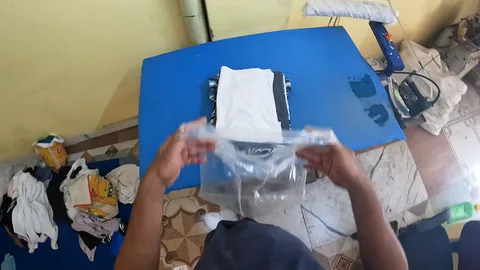
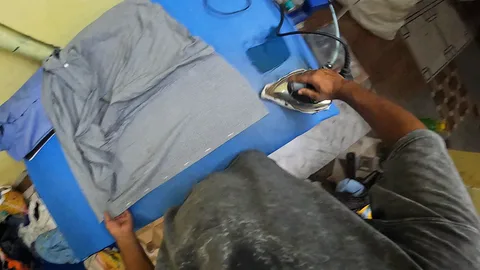
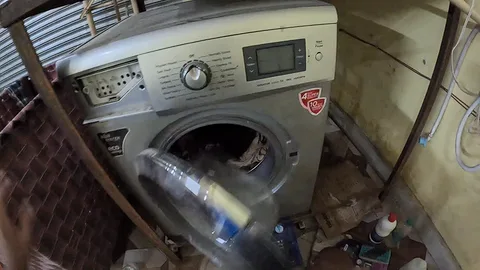
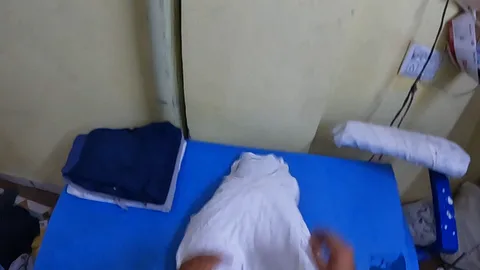
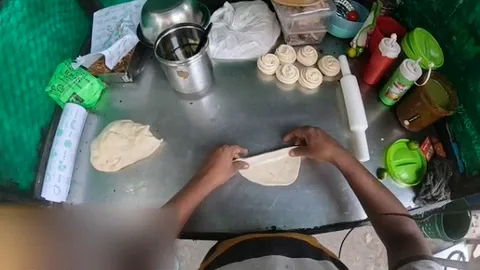
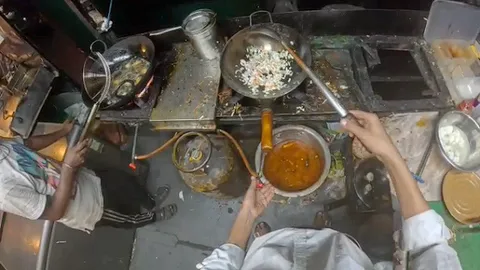
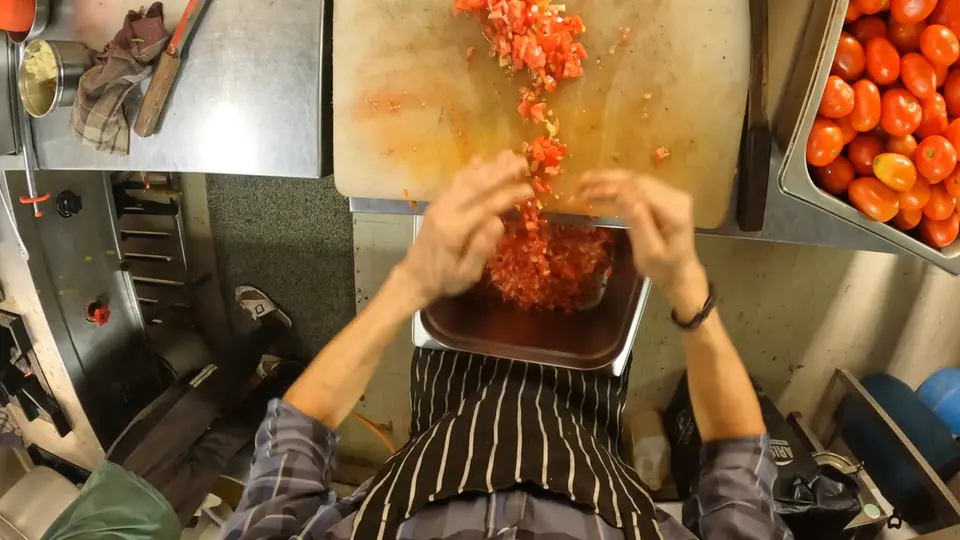
01 Capture
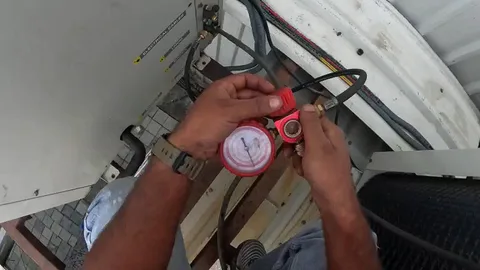
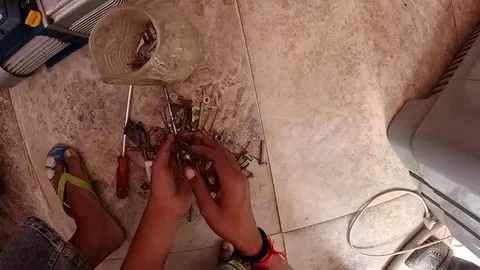
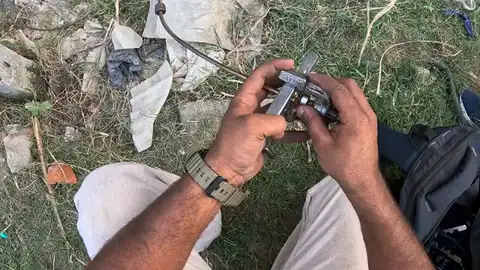
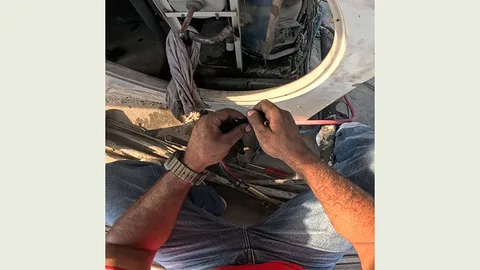
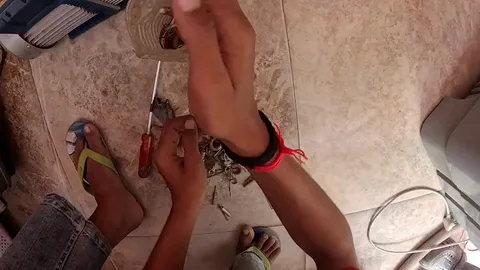
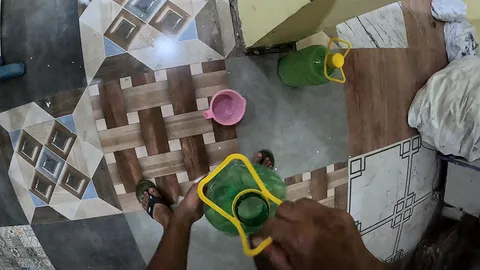
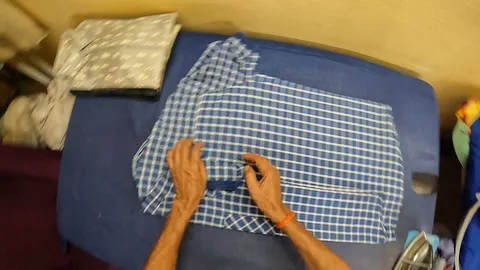
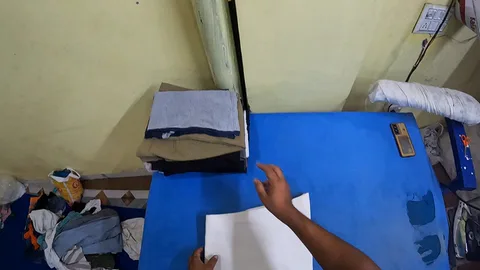
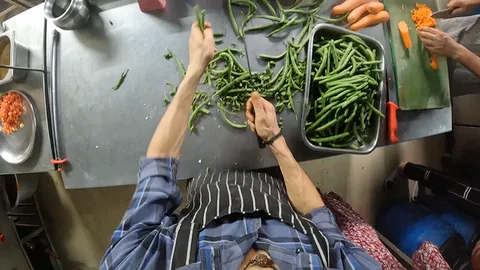
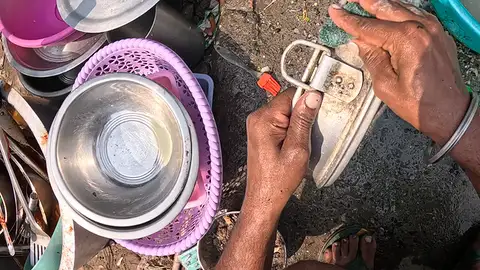
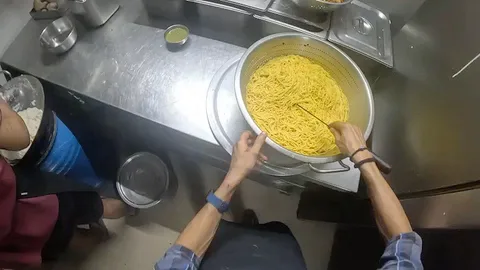
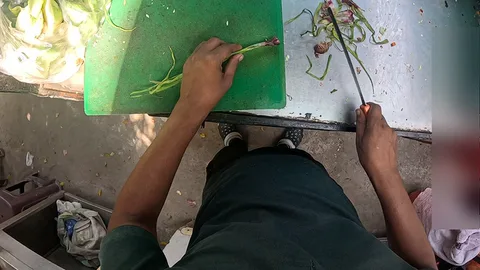
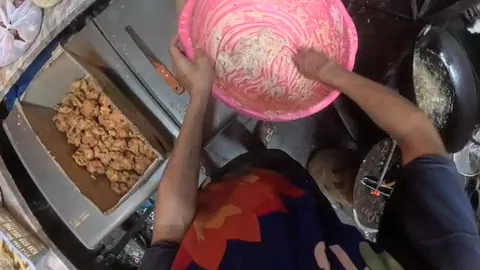
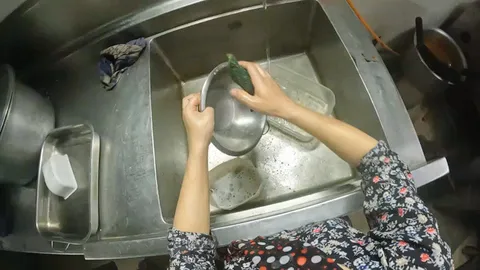
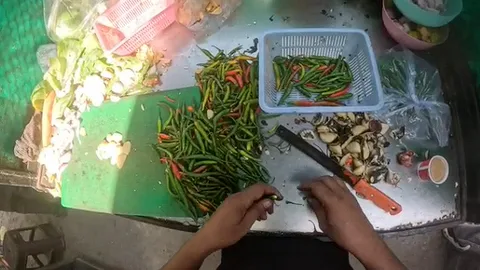
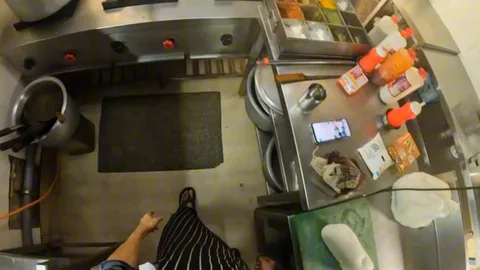
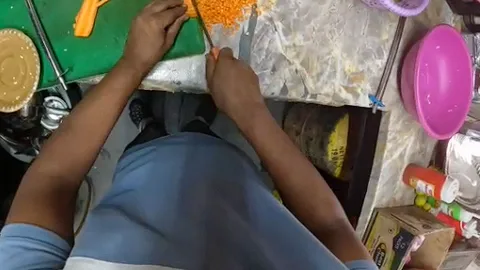
From the worker's head, about where a robot's head camera sits.
- resolution
- 2704×1520
- frame rate
- 50 fps
- codec
- hevc
- telemetry track
- GPMF
- camera
- head-mounted
World models learn to predict it. Robots learn to do it.
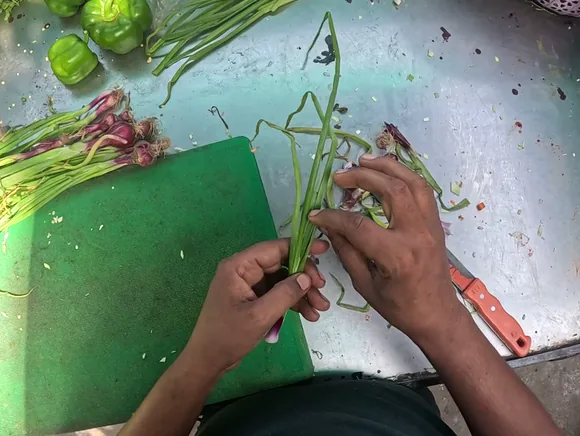 Real footage2704×2028 · 59.94 fps
Each robot frame is retargeted from the worker's hand pose in the same video frame.
Backed by NVIDIA Inception · Georgia Tech CREATE-X
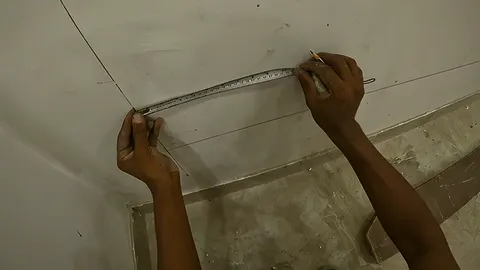
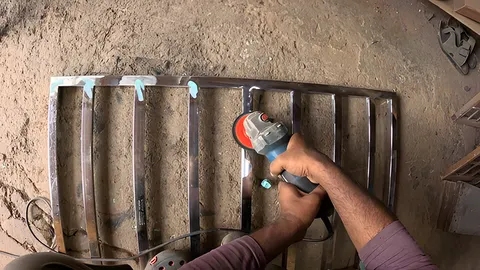
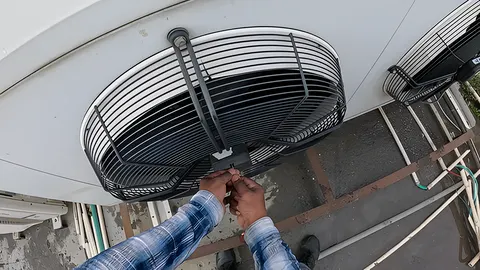
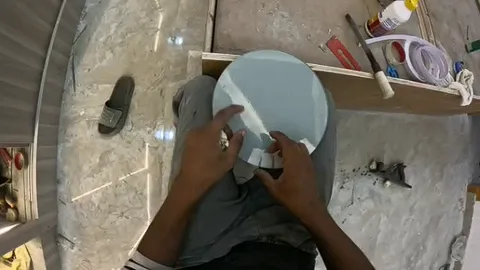
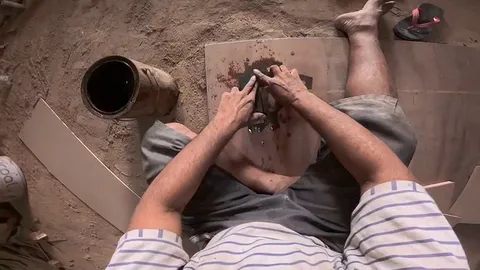
Fig. 1 Real trades, keeping time. You get the camera originals.
100k+
hours of real work
filmed first person
10B+
video frames
from the worker's own view
354
distinct task activities
in the active capture pipeline
200 Hz
motion data
on the video's clock
Hover to play. Click to open.Click one to open.Tap one to open.
Footage: A show of hands
Estimated hand poses, retargeted frame by frame to simulated robot hands.
Render: Robot replay, FV-B00476 · 20.0–28.0 s
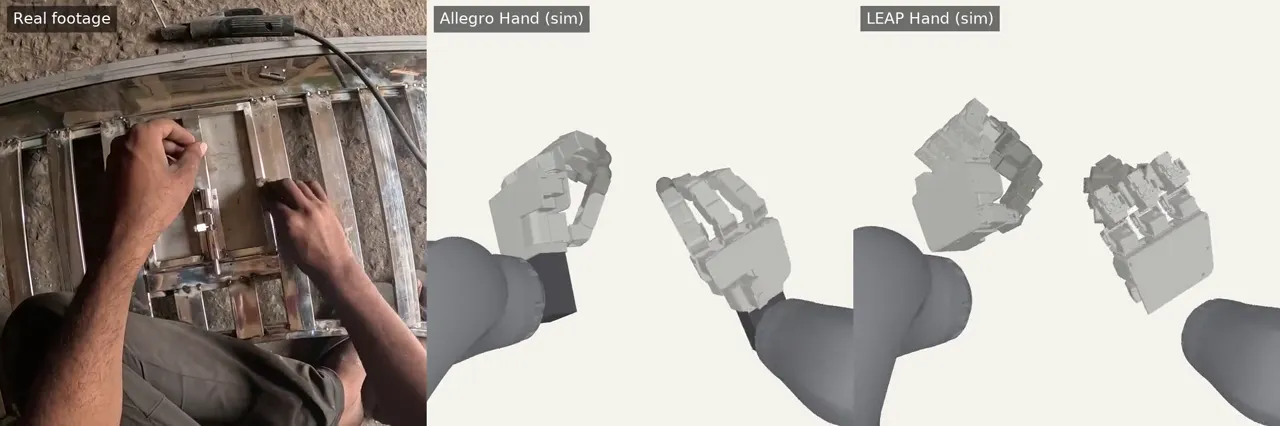
k 0 / 239 · source frame 1200 · 20.020 s
Frames solved 1 / 1
Render of our pipeline output. Left: camera frames (re-encoded). Right: simulated robot hands, not camera footage.
| Trial | Clip | Hands | Frames with a robot pose | Note |
|---|---|---|---|---|
| Spring onions | FV-B01149 · 958.1–966.1 s | both | 240/240 on all four arms | Left-hand grip followed loosely (aperture correlation r -0.25 on the Allegro). |
| Latch | FV-B00476 · 20.0–28.0 s | both | 240/240 on all four arms | The two robot hands pass into each other in 54 Allegro frames (up to 11.5 mm) and 11 LEAP frames (up to 6.8 mm). |
| Green beans | FV-Z00907 · 20.0–28.0 s | right | 186/240 on both robots | Right hand only. k 184-237: no hand estimate, held and greyed on both robots. |
| Shallots: on Why Ego | ||||
Simulated arms, not speed-limited; no object is modelled, so nothing is held.
Two hours of footage, estimated. Eight of 16 directions hold 91.8% of the variance.
Mixed: Hand-posture prior, guided tour
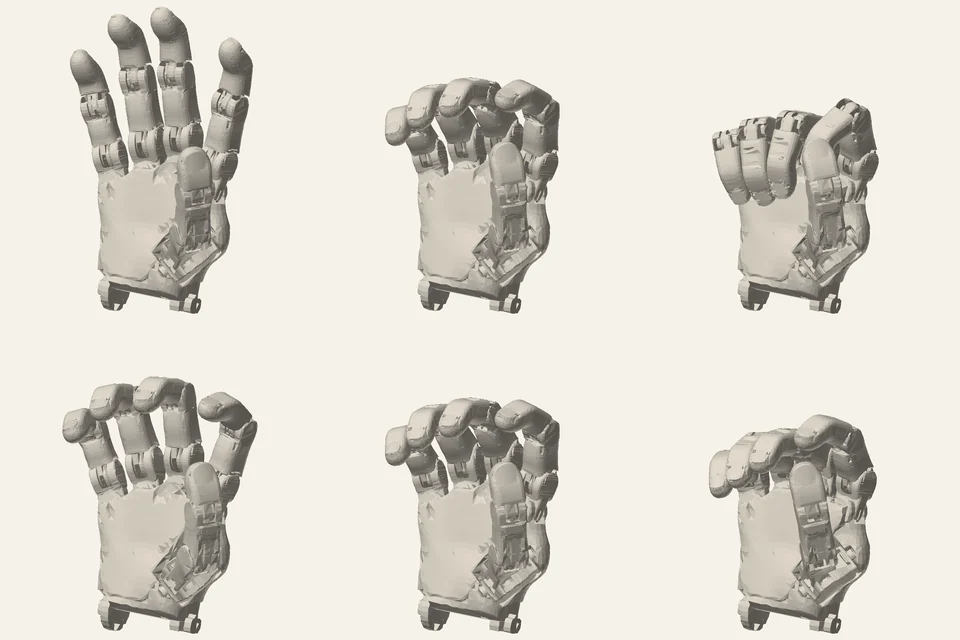
Footage · FV-B01149 · 958.1–966.1 s
k 0 / 239
The nearest real hands from each trade along PC1:
−2σ0+2σ
oursnaive close-all-fingers basisrandom subspaces, 95th percentile
At one direction, ours is no closer than a naive guess (0.490 against 0.488).
| k | ours v0.1 | naive | random 95th percentile |
|---|---|---|---|
| 1 | 0.49 | 0.4882 | 0.239 |
| 2 | 0.8103 | 0.3764 | 0.274 |
| 3 | 0.5693 | 0.295 | 0.315 |
| 4 | 0.5372 | 0.2427 | 0.359 |
| 5 | 0.5818 | 0.2357 | 0.419 |
| 6 | 0.614 | 0.3811 | 0.466 |
| 7 | 0.6276 | 0.4173 | 0.514 |
| 8 | 0.6759 | 0.5563 | 0.571 |
| 9 | 0.7459 | 0.6139 | 0.623 |
| 10 | 0.7692 | 0.7033 | 0.68 |
| 11 | 0.8266 | 0.7425 | 0.733 |
| 12 | 0.8666 | 0.8042 | 0.787 |
| 13 | 0.8879 | 0.8408 | 0.84 |
| 14 | 0.9042 | 0.9135 | 0.895 |
| 15 | 0.9349 | 0.9368 | 0.95 |
| 16 | 1 | 1 | 1 |
A finding about hands at work, not a training result.
Principal directions of 16 finger joints on the ORCA v2 hand model, from estimated poses in four trades.
| PC | 1 | 2 | 3 | 4 | 5 | 6 | 7 | 8 |
|---|---|---|---|---|---|---|---|---|
| share | 42.9% | 16.8% | 9.4% | 7.0% | 5.1% | 4.5% | 3.1% | 2.9% |
| cumulative | 42.9% | 59.7% | 69.1% | 76.1% | 81.2% | 85.8% | 88.9% | 91.8% |
| trade | k90 | PC1 share | pooled top 8 | own top 8 |
|---|---|---|---|---|
| Kitchen | 7 | 43.8% | 92.6% | 93.3% |
| HVAC and electrical | 8 | 46.5% | 91.9% | 92.2% |
| Carpentry | 7 | 47.9% | 92.0% | 92.5% |
| Welding and fabrication | 8 | 33.3% | 89.4% | 90.4% |
Real shifts. Real tasks.
Camera files, motion included.
Gravity included.
Ten seconds of real work, layer by layer.
From the worker's head, about where a robot's head camera sits.
Every head move, felt 197 times a second.
Every task named and coded.
Move the playhead. Five streams follow, on one clock.
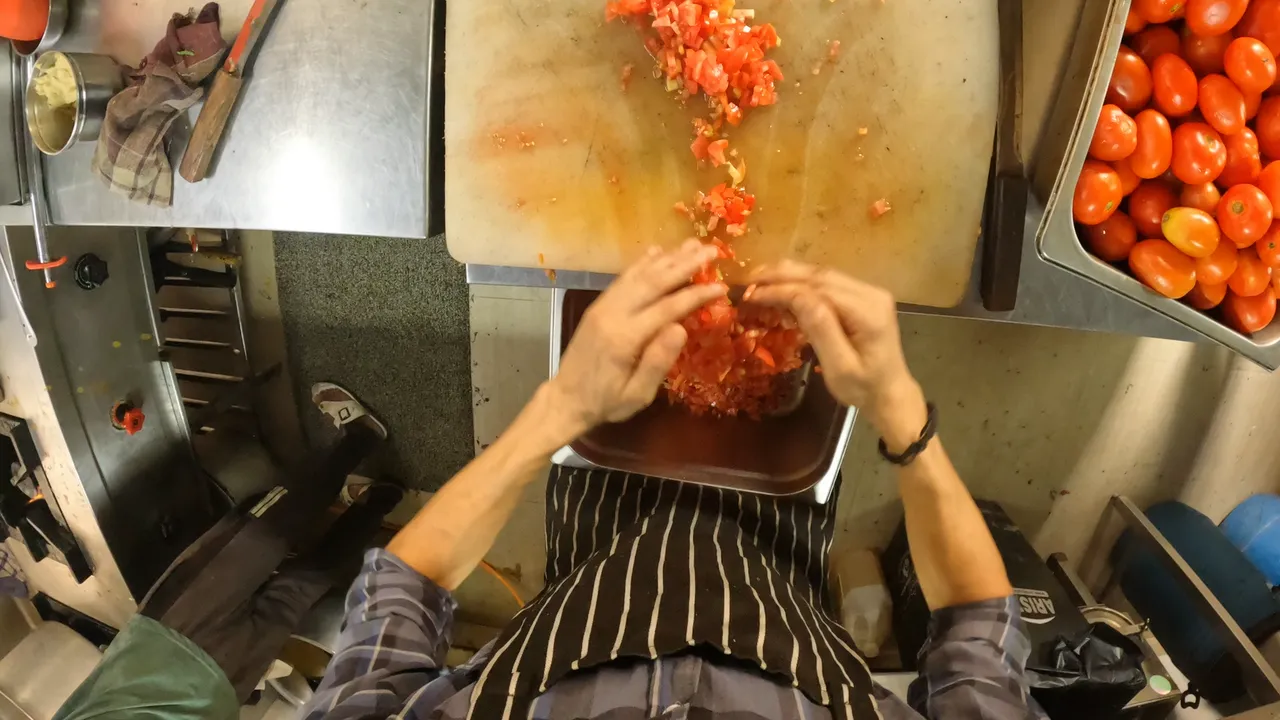
metres · —
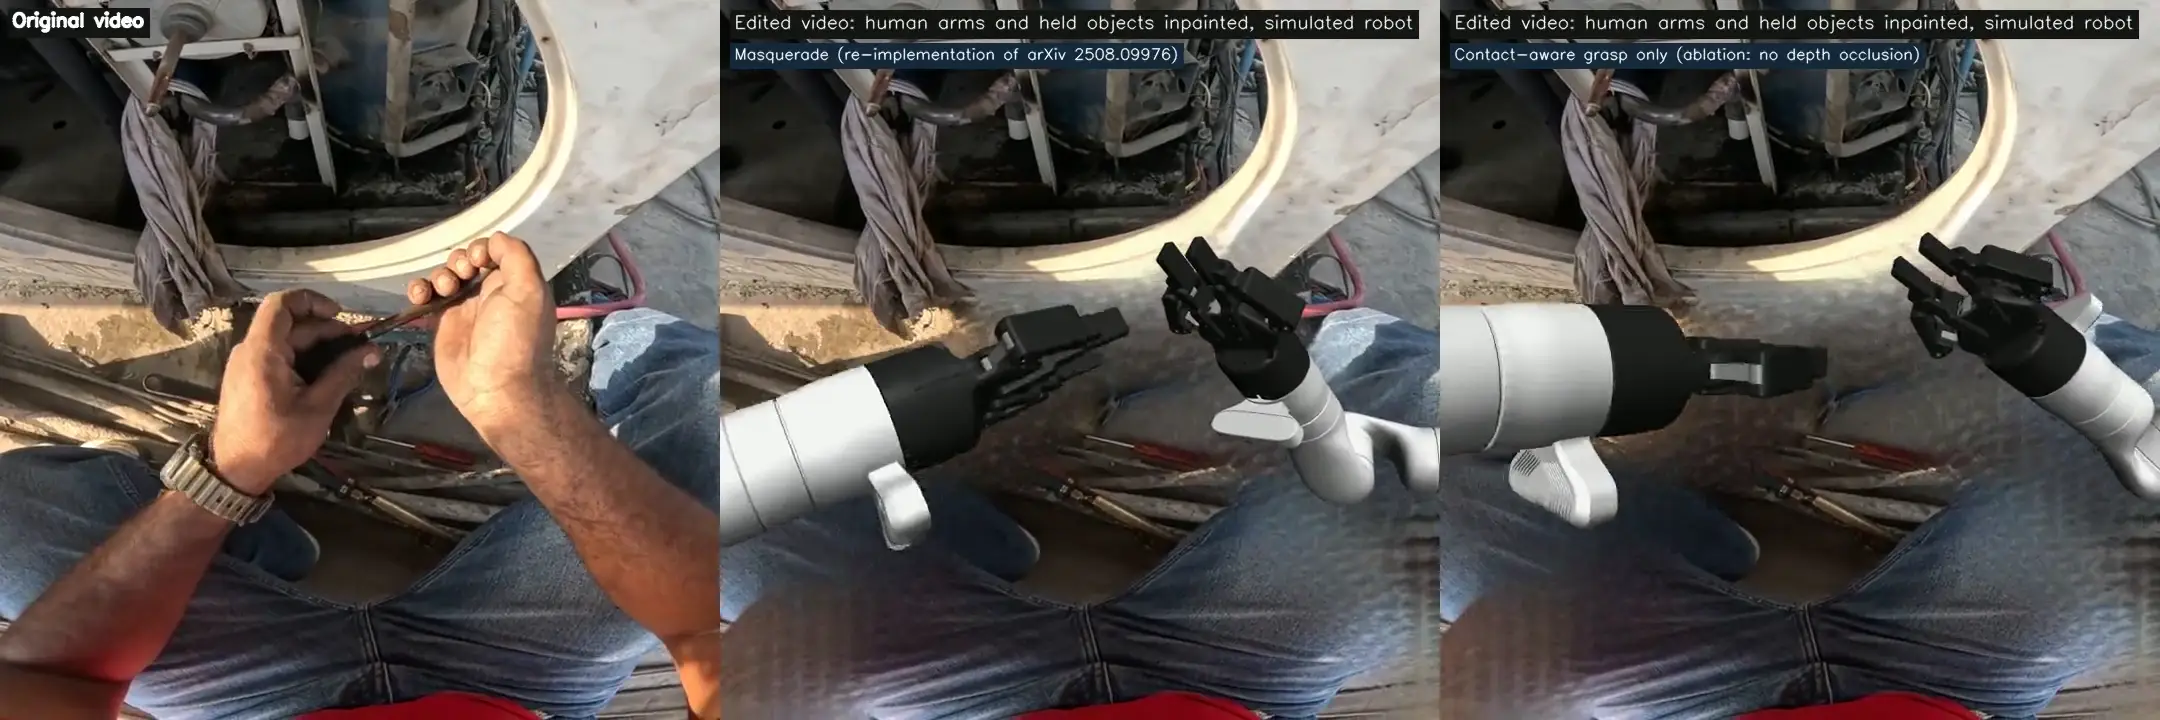
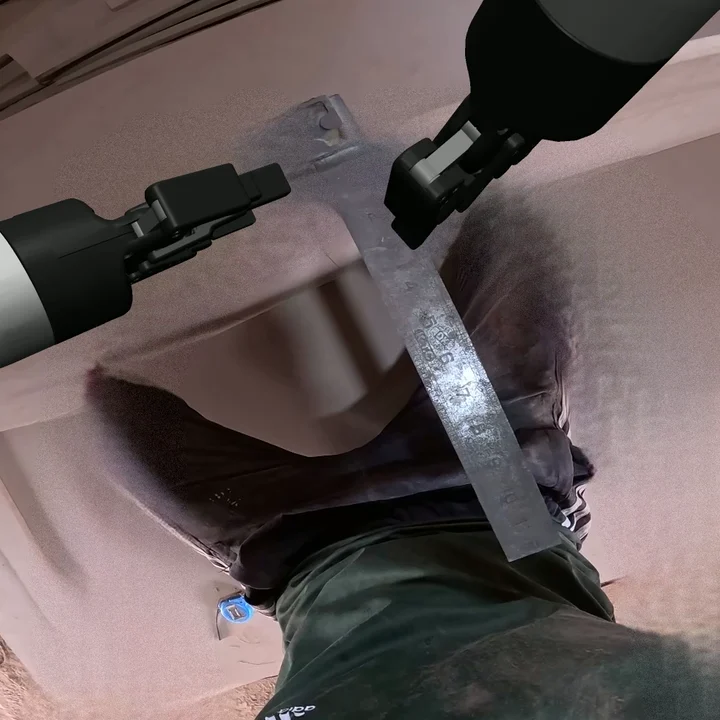
Our re-implementation of Masquerade paints the arms out and draws a robot in.
Edited footage: Camera frames against edited footage, FV-C01442 · 171.8 s
Edited footage: the arms are painted out by a model and a simulated robot is drawn in. Not robot footage.
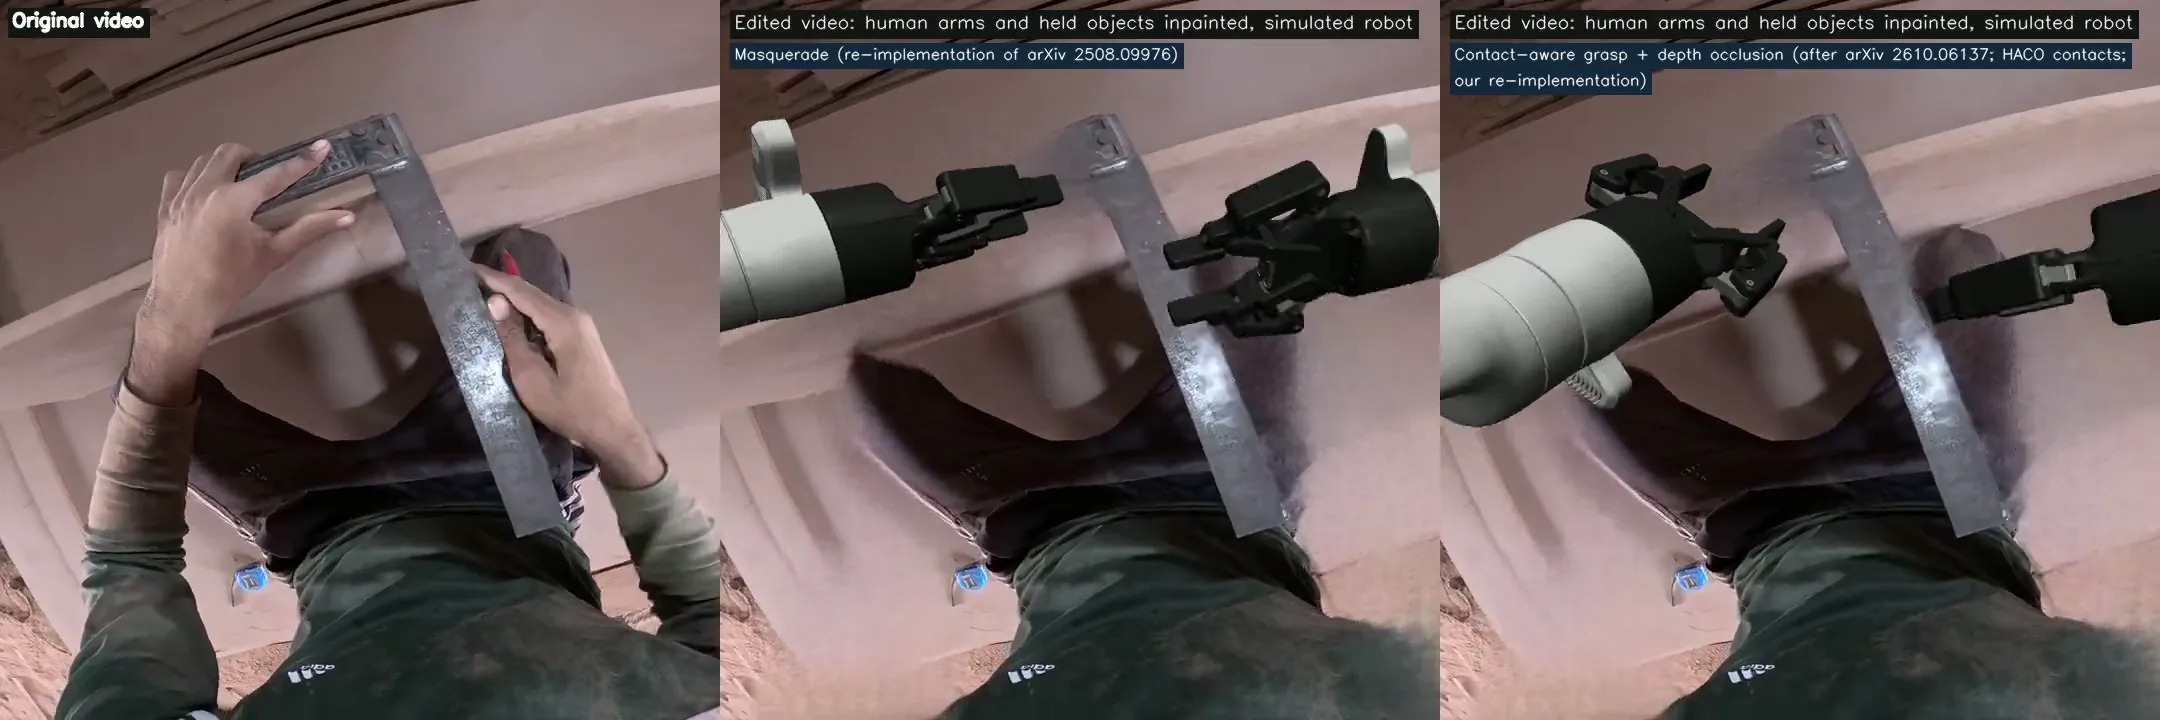
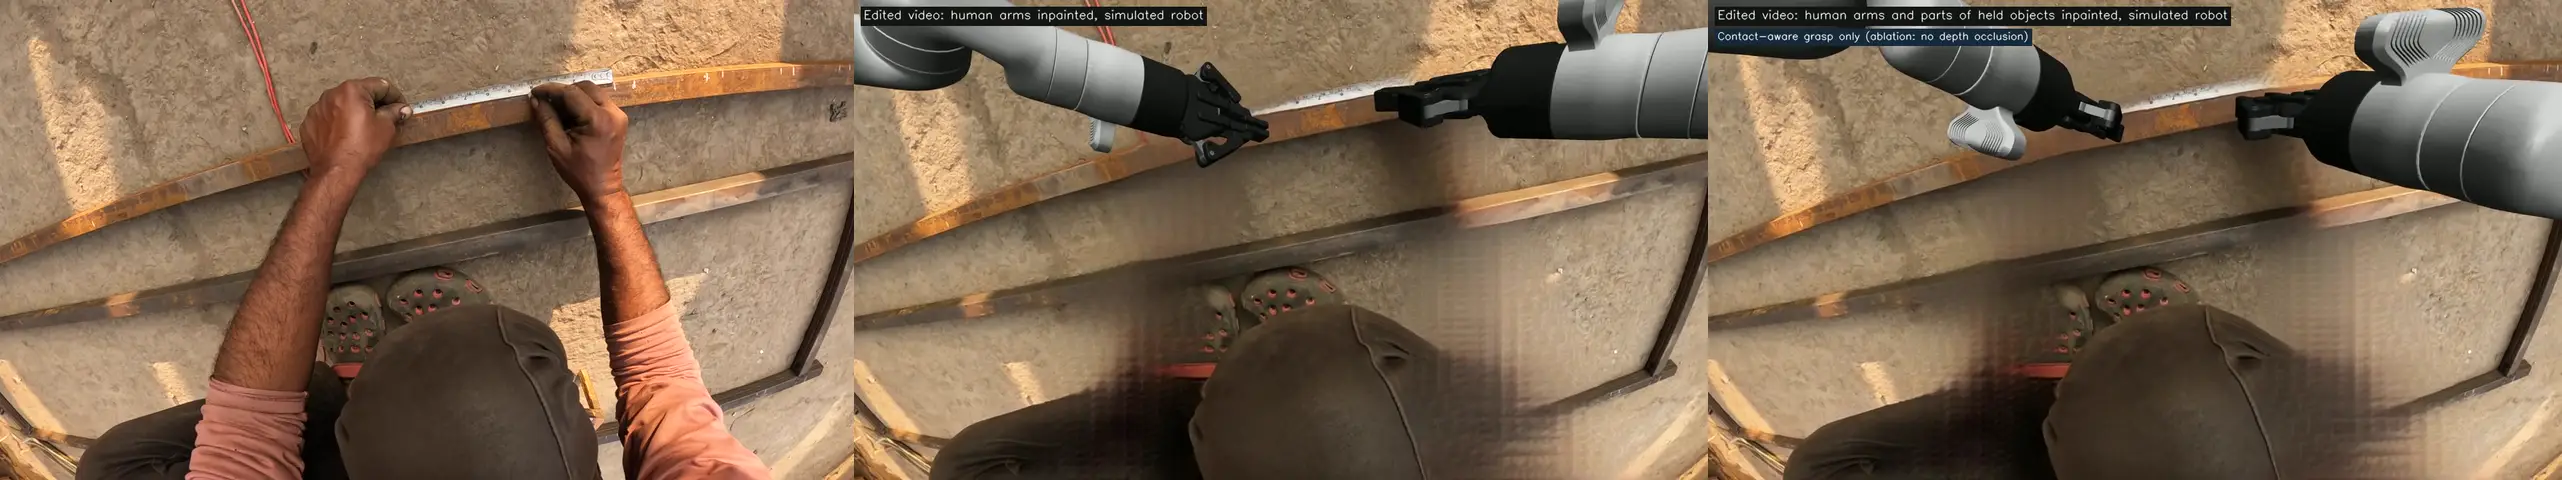
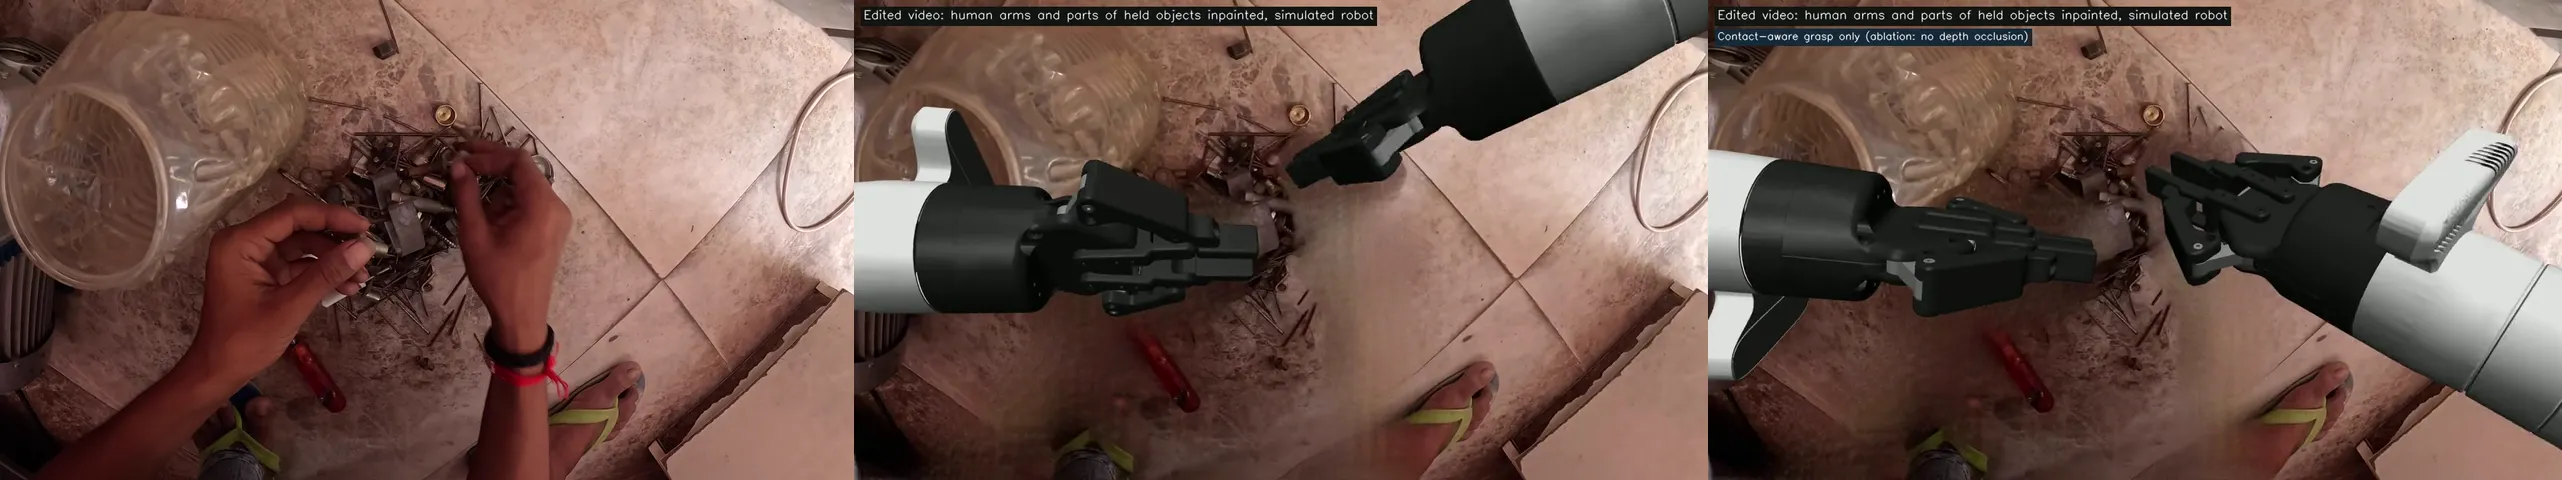
No gripper visibly holds anything.
Edited footage: the arms are painted out by a model and a simulated robot is drawn in. Not robot footage.
Edited footage: Mind the sleeve
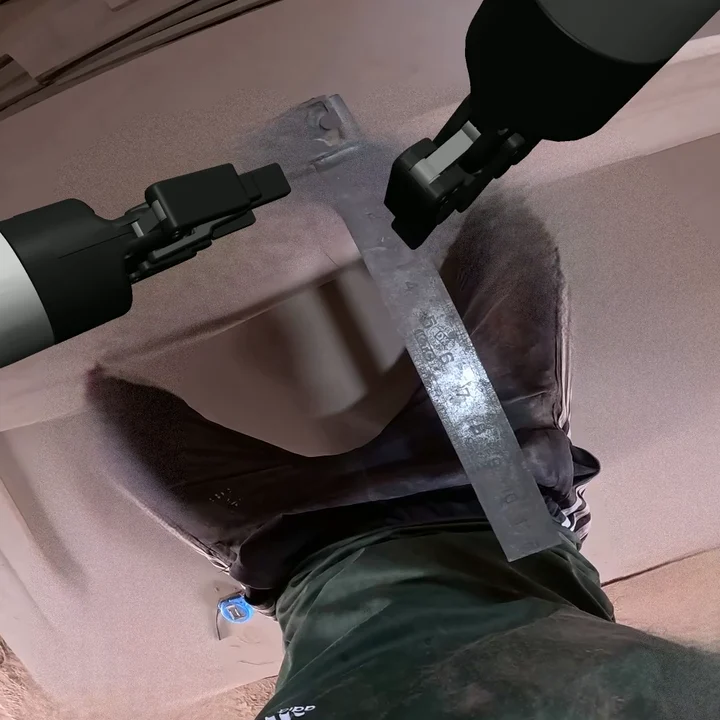
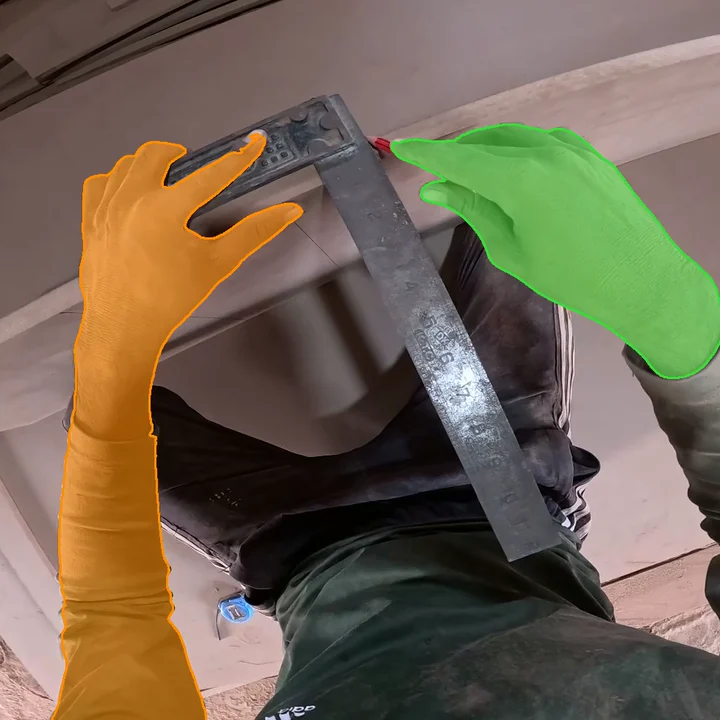 One point per handThe masks stop at the hands; most of each arm would stay human.
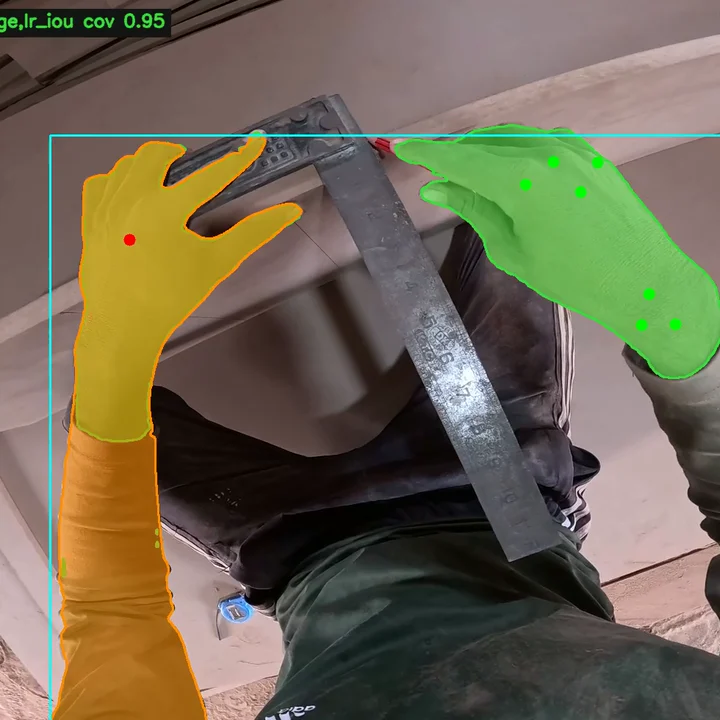 Along the forearmHands and bare forearms are covered, up to the sleeve cuff.
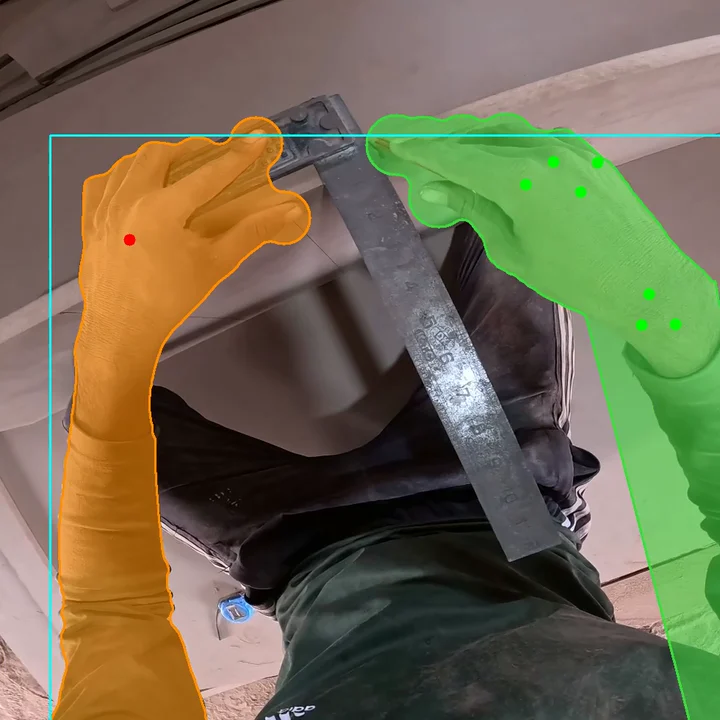 Hand to frame edgeSleeves included, but the outer half of the right cuff is missed in many frames.
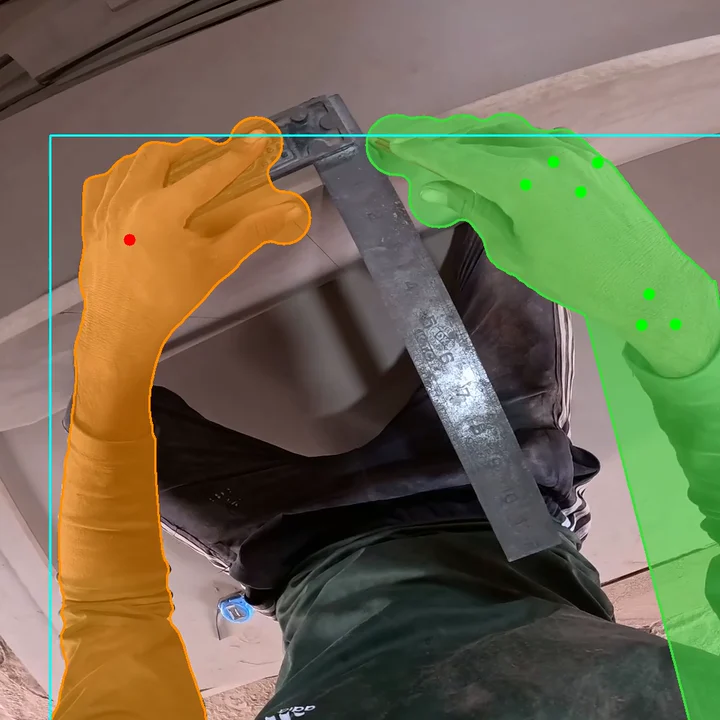 Sleeve regrownGrown back inside a corridor from the wrist: the right mask no longer stops there.
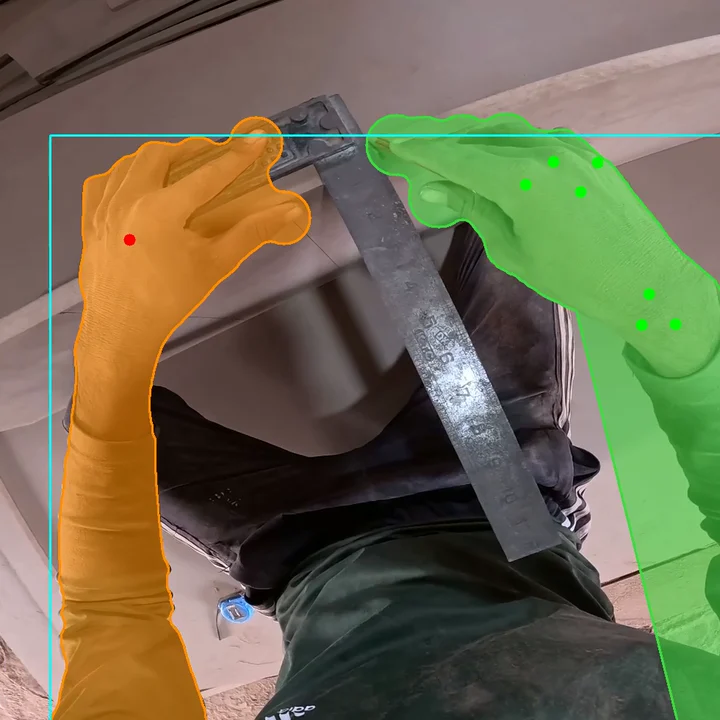 Outline closedAn arm hull closes the right arm's outline and its one-frame cuff misses.
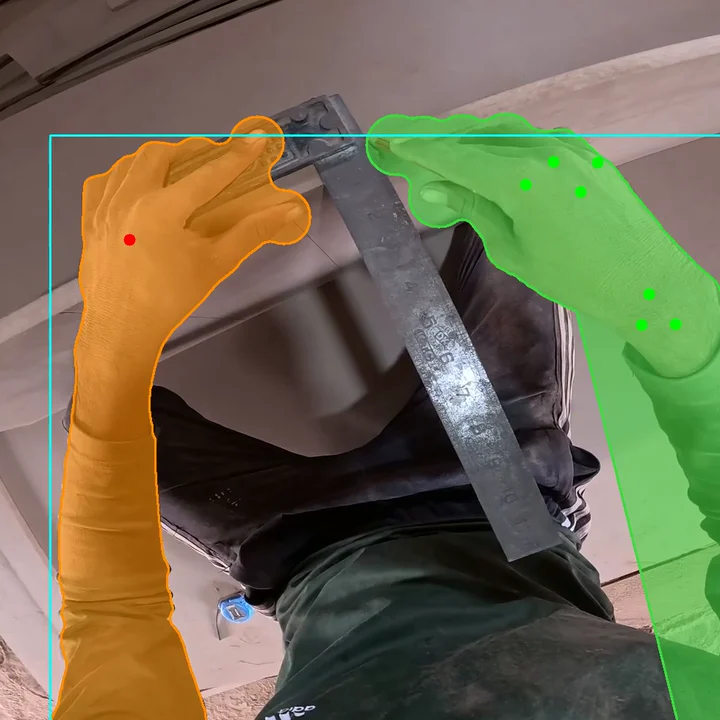 Neighbours voteA pixel both neighbouring frames mask is added; it only adds pixels, never moves the robot.Composite, fix offA strip of the right sleeve stays human at the arm's outer edge.Composite, fix onThe sleeve strip is gone; the fill still smears where no frame shows the floor.
Mind the sleeve. A mask that stops at the cuff leaves a human sleeve behind.
Edited footage: Contact-aware against Masquerade
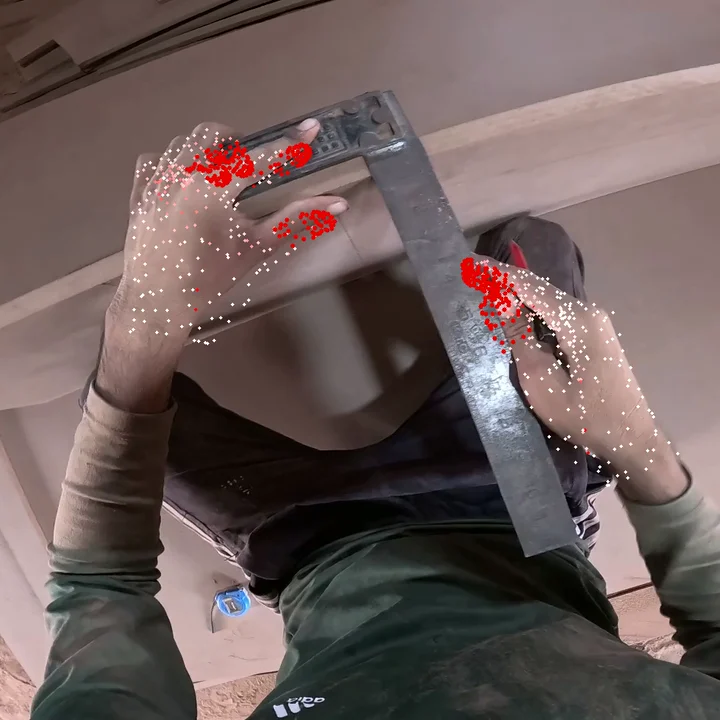
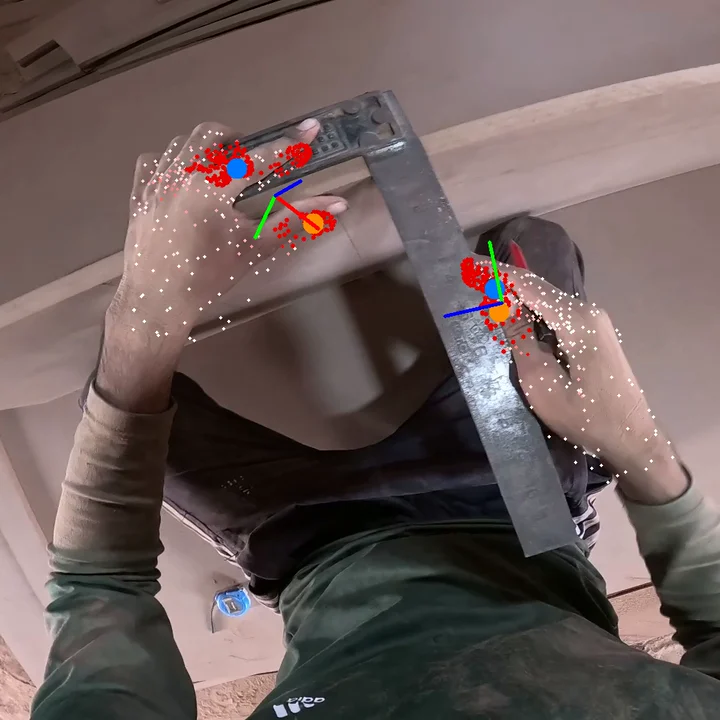
Aimed at the touch. Pads moved onto another model's contact estimates. Not measured contact.
| Clip | Contact-aware, right | Contact-aware, left | Masquerade, right | Masquerade, left |
|---|---|---|---|---|
| Carpentry FV-C01442 | 5.4 / 6.5 | 1.9 / 2.3 | 25.3 / 35.8 | 30.1 / 44.9 |
| HVAC FV-C01720 | 3.9 / 4.6 | 2.9 / 3.3 | 14.4 / 24.4 | 19.1 / 38.9 |
| Metal FV-B01919 | 2.0 / 2.9 | 1.4 / 1.7 | 12.5 / 23.8 | 20.0 / 15.7 |
| Small parts FV-B01174 | 3.5 / 4.2 | 2.2 / 3.2 | 15.2 / 16.8 | 14.5 / 14.8 |
| Kitchen (on Why Ego) FV-B01774 | 4.5 / 5.8 | 2.2 / 2.4 | 19.9 / 42.6 | 19.3 / 13.5 |
The camera original, its IMU on the video clock, labels and metadata.
Measured, or labelled estimated.
Camera motion is measured. Hand pose and head position are labelled estimates.
Your format.
LeRobot v3, RLDS, HDF5 or MCAP, beside the originals. More sensors per quote.
Only footage an independent expert confirms meets your criteria is billed. Set your criteria
Free for teams evaluating a purchase. We reply within one working day.
FV-Z00908.MP4
2704×1520 · 50 fps704 s · hevc · GPMF
FV-Z00908_imu.csv
timestamp_us,ax, ay, az,gx, gy, gz138,653 rows196.95 Hz measured
FV-Z00908_labels.json
"taxonomy_version": "1.0.0","segments": [ …, { "code": "10.1.06", "name": "Mise en place setup", "start_us": 408000000, "end_us": 414000000, "provisional": true }, { "code": "10.1.01", "name": "Vegetable washing and chopping", "start_us": 414000000, "end_us": 418000000, "provisional": true }, … ]10.1.06 · 10.1.01provisional
Search by task or code, or open a workplace.
Acceptance gates. Both hands in frame for 90% of a clip, no idle stretch over 10 s, identifiable faces in at most 5% of frames. Every published gate
Consent. Every worker signs a licence for machine-learning training; minors are excluded; sites and workers are pseudonymised. The consent policy